Scientists built a robotic hand that can walk on its fingertips and even type while balancing
An ETH Zurich team taught a robotic hand to walk on its fingertips, recover from falls and press keyboard keys while staying upright.

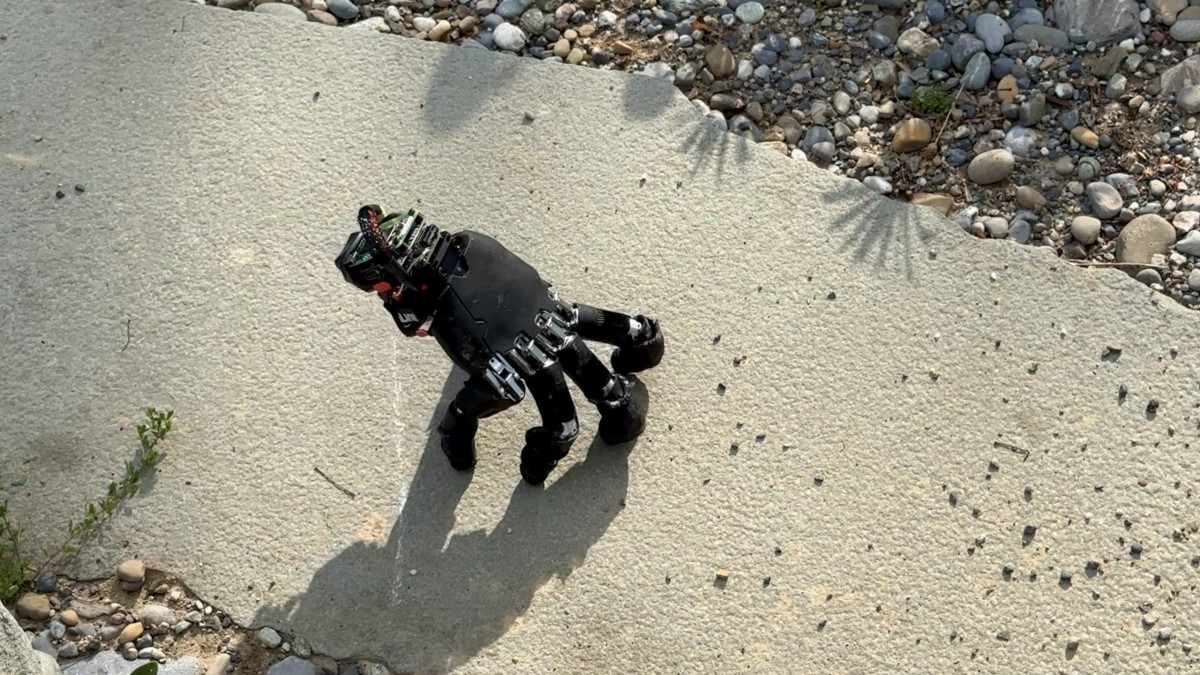
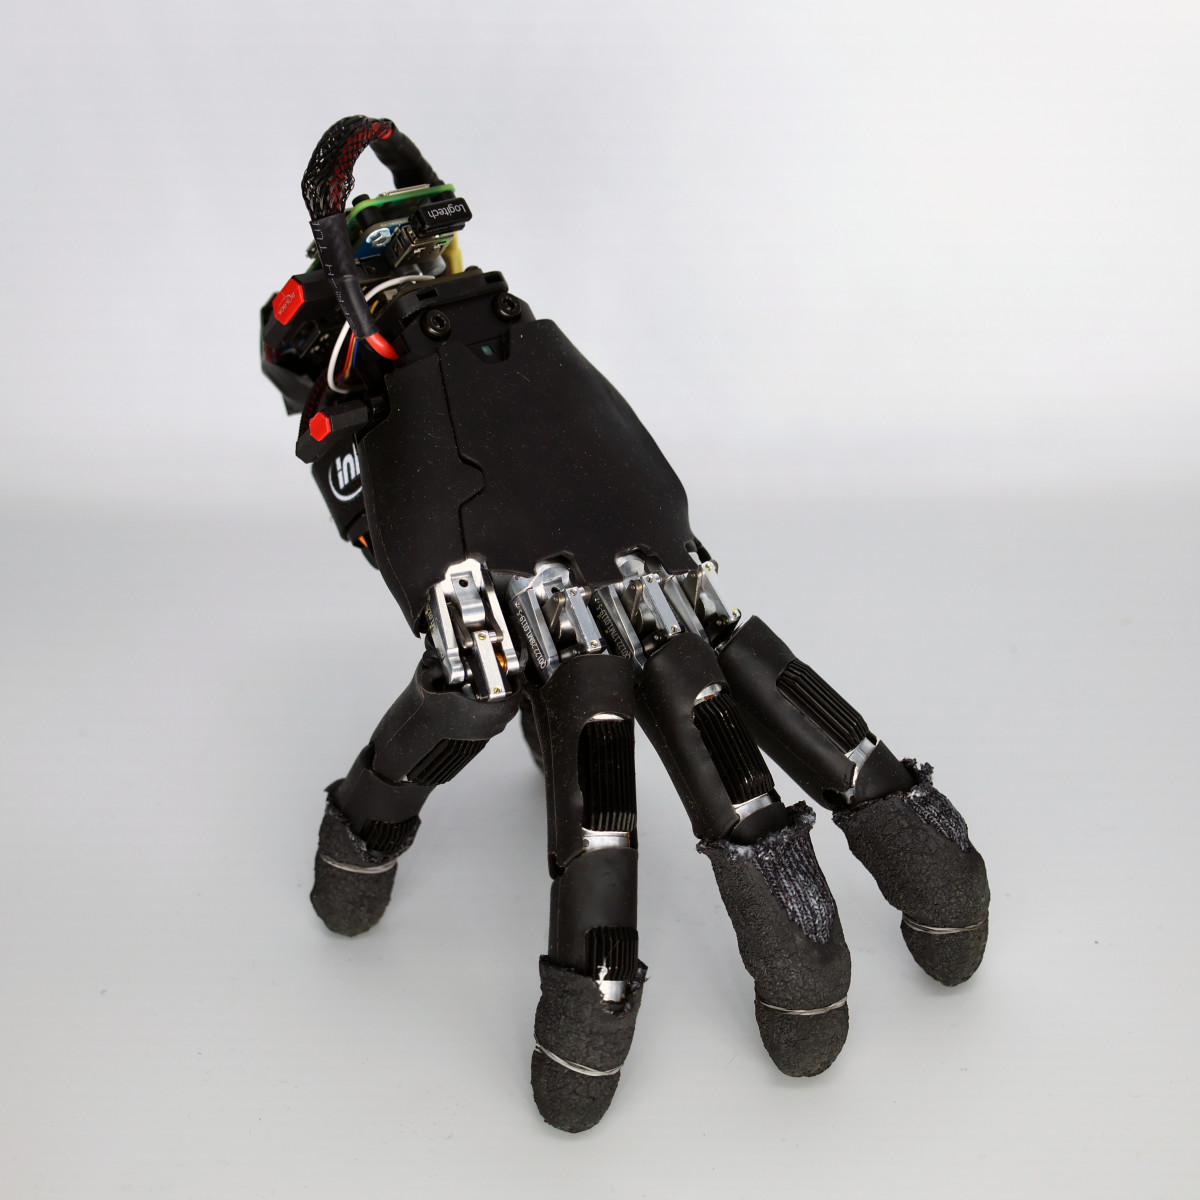
The unsettling part is how familiar it looks. A robotic hand from a Swiss lab can scuttle forward on its fingertips, recover after a fall and even tap a keyboard key while the rest of it stays balanced.
At first glance, it lands somewhere between a lab demo and a horror prop. Watching a hand move by itself on its fingers immediately calls to mind Thing from The Addams Family, the same pop culture image that has kept turning up whenever severed-hand costumes make the rounds.
This version, though, was not built for Halloween. Researchers at ETH Zurich are trying to give robotic hands a new kind of job: moving into places a larger robot cannot reach, then doing useful work once they get there.
A hand that goes where the rest of the robot cannot
In the clip below, the researchers show the hand carrying out the fingertip walking and balancing they trained it to do.
The idea behind the project is simple even if the mechanics are not. Instead of treating a robotic hand as the end of an arm that always has to carry it into position, the team wanted the hand itself to become mobile. Their longer-term goal is a system that could send a hand into a confined space to inspect something, operate a control or move an object, then bring it back afterward.
That meant teaching one machine part to do two different jobs at once. Robotic hands are already capable of delicate manipulation, but here the same fingers also had to support the hand's weight, keep it balanced and provide movement across the ground.
The team explored those abilities using a commercially available WUJI robotic hand rather than redesigning the fingers from scratch. They added a battery, a small computer and a motion sensor. Altogether, the setup weighed 818 grams, about 1.8 pounds, with the power and computing hardware mounted on the back of the hand.
Why walking on fingers is harder than it sounds
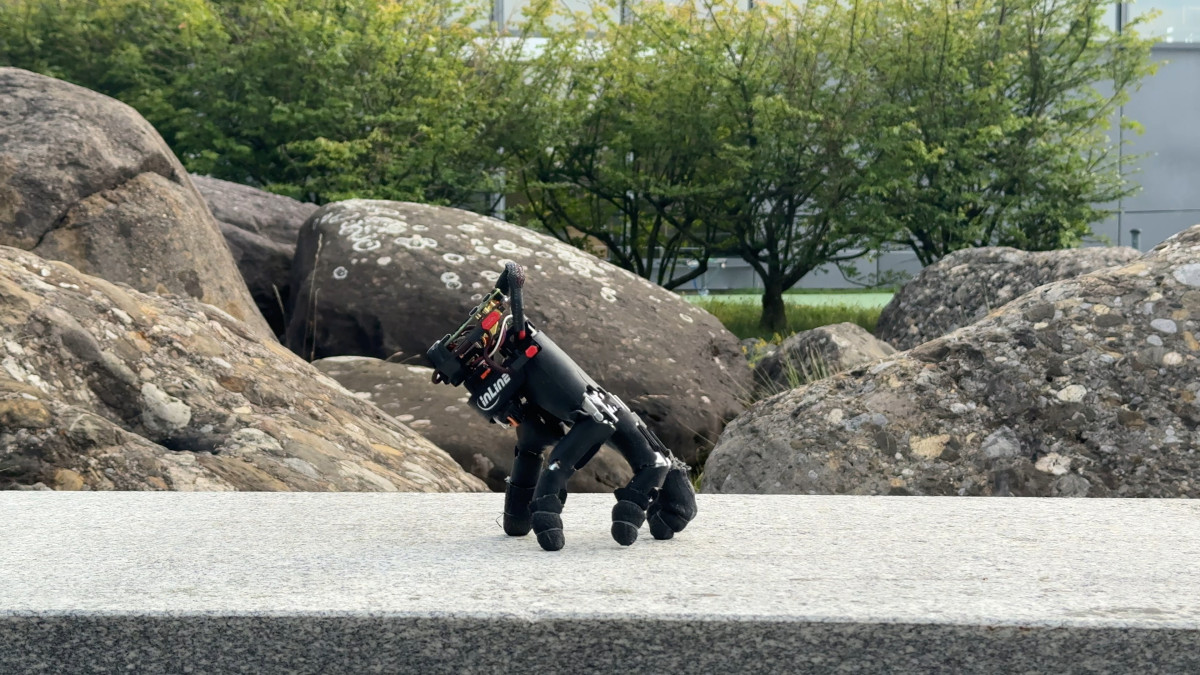
Human hands are not naturally shaped like tidy four-legged robots, and the researchers had to work around that. The fingers are different lengths, and the thumb sits off to one side. That makes the whole arrangement awkward for walking, especially when the hand also has to stay steady enough to interact with objects.
The balancing problem is easy to demonstrate with your own hand. If only your fingertips are touching a table and one finger lifts, the others have to compensate to keep everything stable. A robotic hand attempting to walk has to keep repeating that shift in support while carrying its full weight.
Before trying it on the physical machine, the researchers trained the control software in simulation using reinforcement learning. In practical terms, the system was rewarded for motions that helped it move in the requested direction and penalized for motions such as excessive rocking that made it less stable.
They also built in a way to account for the hand's uneven shape. Each fingertip was given a reference position based on the hand's resting stance. Moving too far from that position reduced the score, although the software allowed more freedom in the direction of travel. That let the system discover a workable gait without being told every individual step.
Getting those simulated movements to work on the real hand required another round of tuning. The team measured how the joints responded to commands and how the fingertips slid against a surface so the training matched the hardware more closely.
From crawling over grass to pressing arrow keys
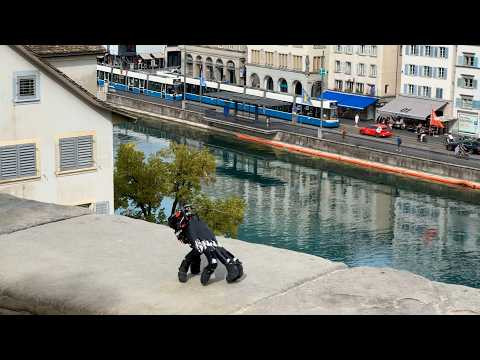
Once trained, the hand crawled across 14 different surfaces in demonstrations. Those included wooden floors, metal grating, grass and gravel. A human operator issued movement commands with a gamepad, while the onboard software handled the detailed coordination of the fingers and balance without camera guidance.
In steering tests on a mat, it averaged 9.3 centimeters per second, or 3.7 inches per second, across 21 runs. The researchers also trained it to get upright again after falling over. In 25 physical trials, it succeeded 21 times. The four failed attempts happened when its fingers caught on one another.
Movement was only part of the challenge. The team also wanted to know whether a finger could leave the ground long enough to do useful work without toppling the hand. Using a separate trained controller, they had it press the correct keyboard arrow key in 29 out of 32 consecutive commands.
That skill was enough for a small but memorable test. A person chose the moves in Sokoban, the box-pushing puzzle game, and the hand entered those moves on a keyboard without visual feedback.
Handling a real object required a different setup. For that experiment, an overhead camera tracked both the hand and a cube, giving the system the information it needed to approach the cube and push it toward a target while staying balanced.
What comes next for the roaming hand
The work is still at an early stage. The study has been posted as a preprint on arXiv and has not yet been peer-reviewed. The researchers also note that each ability currently relies on its own trained controller, so the next step is combining those separate skills into longer sequences of action.
They also want to improve reliability and add onboard vision. And while the hand was demonstrated outdoors, those tests do not yet show how consistently it would deal with unfamiliar terrain.
Other ambitions remain further off. The team is interested in automatic detachment from a larger robot and reconnection afterward, which would make the hand more like a temporary scout than a permanently separated machine. One researcher also pointed to the possibility of muscle-like mechanisms that could help a robotic hand adjust its stiffness for gentler contact.
For now, the result is a machine that looks strange precisely because it is doing something hands are not supposed to do on their own. But the point is not just the creep factor. It is that a hand that can walk, recover, balance and work could eventually reach into the kinds of tight spaces where a whole robot body simply will not fit.